Automated Storage
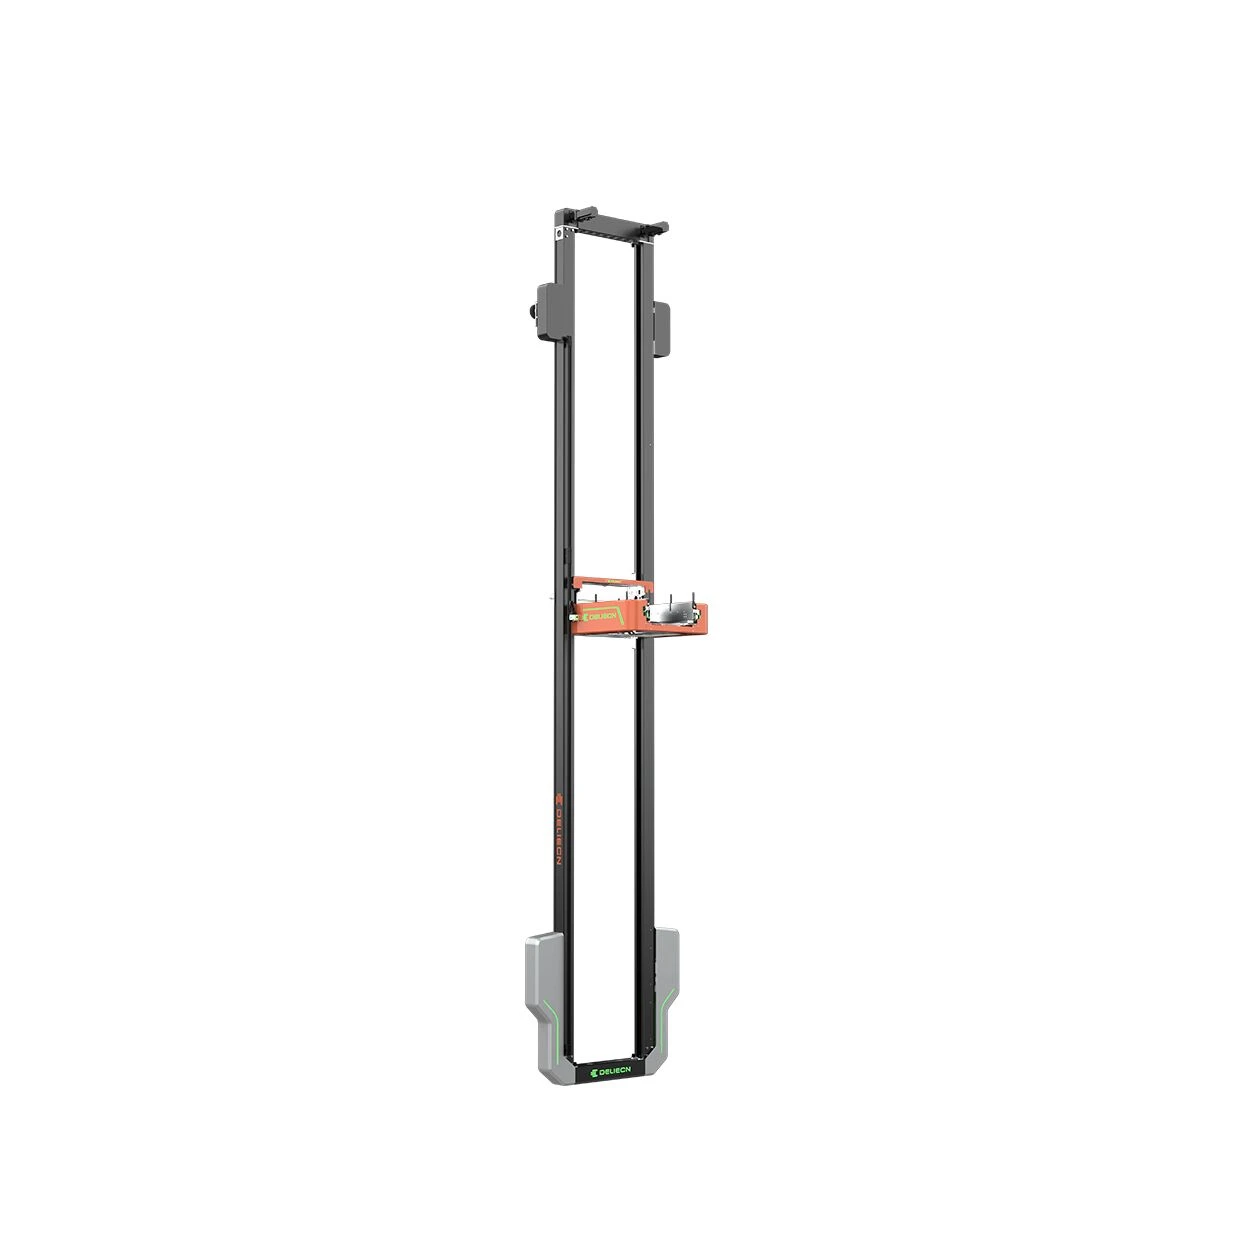
Mini-FlyBox
A tote-handling robot combining horizontal rail travel, vertical lifting and a goods platform.
Key characteristics
- A tote-handling robot combining horizontal rail travel, vertical lifting and a goods platform.
- Confirm the selected configuration, load and interfaces against project requirements.
Specifications
Values apply to the configurations shown; they are not guaranteed project throughput.
| Parameter | Single Deep | Double Deep |
|---|---|---|
| Dimensions (mm) | 1600*760*H (Customized) | 1600*1000*H (Customized) |
| Max. Payload (kg) | 50 | 50 |
| Max. Walking Speed (m/s) | 3 | 3 |
| Max. Walking Acceleration (m/s²) | 2 | 2 |
| Max. Lifting Speed (m/s) | 3 | 3 |
| Max. Lifting Acceleration (m/s²) | 2 | 2 |
| Max. Telescoping Fork Speed (m/s) | 1 | 1 |
| Standard Tote Dimension (mm) | 600x400 | 600x400 |
| Aisle Width (mm) | 860 | 1100 |
| Walking Drive Motor | Servo Motor | Servo Motor |
| Lifting Drive Motor | Servo Motor | Servo Motor |
| Telescoping Fork Drive Motor | Servo Motor | Servo Motor |
| Communication Method | WIFI | WIFI |
| Walking Positioning Method | Barcode | Barcode |
| Walking Control Method | Closed-Loop Servo Control System | Closed-Loop Servo Control System |
| Power Supply | Conductor Rail | Conductor Rail |
| Operation Mode | Automatic Mode / Manual Mode | Automatic Mode / Manual Mode |
| Ambient Operating Temperature (°C) | -25~+45 | -25~+45 |
Configuration notes
Selected-model limits and operating conditions require confirmation; unresolved technical values are withheld.
Solution design & integration
CoreLogis develops the operating concept, selects suitable technology and coordinates system integration.
High-Density Storage & Retrieval